DJI 2026 RoboMaster Sentry Robot Navigation System — Target Tracking
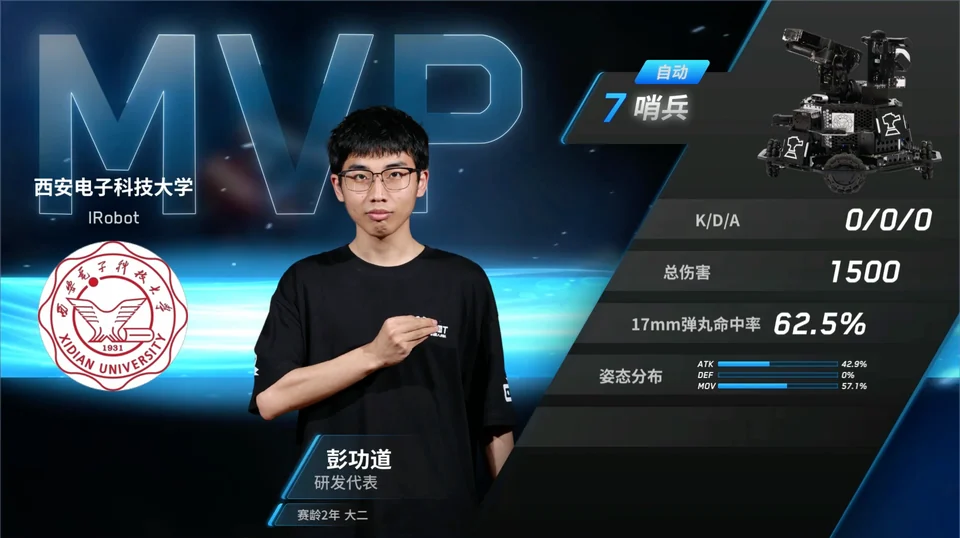
Developed a target-tracking planner for XDU IRobot’s sentry robot, adapting Elastic-Tracker with MINCO trajectory optimization and ROS 2 / Nav2 integration.
I'm an undergraduate at Xidian University (2025-2029), majoring in Intelligent Science and Technology. I lead the algorithm team at IRobot (XDU RoboMaster Team).
I'm currently exploring robot autonomous localization and navigation.
Feel free to reach out to me: zhijunz@stu.xidian.edu.cn
Developed a target-tracking planner for XDU IRobot’s sentry robot, adapting Elastic-Tracker with MINCO trajectory optimization and ROS 2 / Nav2 integration.
An open-source mathematical modeling workflow for Claude Code and Codex, with method validation, code review, and reproducibility checks.
I share notes from the books and courses I'm studying.